British engineering company MGI Engineering has introduced SeaGlide-an autonomous electric vessel that utilises hydrofoil technology for high-speed, low-signature maritime operations.
The uncrewed surface vessel includes advanced control systems and uses Formula One-derived composite materials to produce a platform capable of intelligence-gathering, surveillance, and logistics missions in high-risk maritime areas.

Utilising electric propulsion, located inside its fins, SeaGlide lifts its hull above the water via adjustable hydrofoils-eliminating hydrodynamic drag and keeping its operations nearly silent. The approach utilised to develop this type of platform solves one of the most common issues in maritime operations - how to balance extended range and high speed without the typical acoustic signature associated with conventional propulsion systems. The platform can operate independently - utilising a beyond-visual-line-of-sight-certified system that includes automatic identification system data, radar, optical sensors, and collision avoidance algorithms.
In addition to the capabilities offered by SeaGlide as a stand-alone platform, the platform’s operational framework includes integration with MGI's Mosquito cargo uncrewed aerial vehicles. This allows support for autonomous cargo transfer - i.e., UAVs can take off from ships or land-based facilities; transfer cargo to SeaGlide vessels at sea; and transport cargo to coastal or island destinations without any human intervention. The system represents an innovative approach to networked uncrewed operations at a time when current defence efforts are exploring multi-domain autonomous systems.
The hydrofoil design of the platform significantly changes how the vessel interacts with water. As the vessel gains speed, water flowing around the submerged foils generates lift using the Bernoulli's principle - the same aerodynamic principle that governs flight.Once the lift generated by the foils becomes large enough, typically at speeds greater than 15 knots, the hull rises out of the water, and only the foils and strut supporting them remain submerged. By doing so, the platform can reduce its wetted surface area by approximately 80% and eliminates a large portion of the drag forces that limit the speed and range of vessels.
The engineering foundation of the SeaGlide hydrofoil system aligns directly with the fundamental concepts of fluid dynamics. When water moves over the curved upper surface of a hydrofoil, it travels farther than the water beneath the foil, creating a velocity gradient.
This velocity gradient establishes a pressure gradient according to Bernoulli's equation - lower pressure above the foil and higher pressure below the foil. The pressure gradient generates a lift force that is perpendicular to the flow direction.
The adjustable nature of the SeaGlide’s foils introduces the complexity of active control that engineering students will recognise from control systems courses. Each foil's angle of attack - the angle between the chord line of the foil and the approaching flow of water - can be adjusted in real-time via servo actuators. The adjustment of each foil's angle of attack can be used to accomplish multiple tasks: to keep the lift-to-drag ratio of each foil optimised for the speed of the vessel; to adjust for variations in the weight distribution of the ship as fuel or cargo is added or removed; and to provide stability control for the boat in varying sea states.
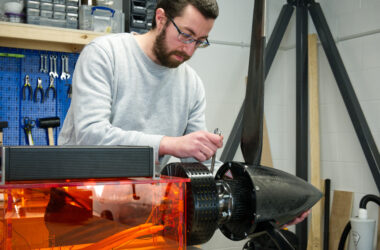
The location of the electric motors within the fins of the SeaGlide represents a engineering decision that solves multiple design constraints simultaneously. First, the motors eliminate the need for traditional driveshafts that extend into the vessel’s hull, thereby reducing the mechanical complexity and potential failure points. Second, the motors utilise direct water cooling, which improves thermal management without the need for additional cooling systems. Third, from a hydrodynamic perspective, locating the propulsion system with the lifting surfaces minimises appendage drag - additional resistance created by the protruding components - while maintaining propulsive efficiency.
The selection of the material for the vessel's structure was critical in achieving the desired performance characteristics. The Formula One-derived composites are likely carbon fibre-reinforced polymers, which have a specific strength (strength-to-weight ratio) approximately five times that of aluminium alloys. The lightweight structure required for hydrofoil operation is enabled by these materials, while maintaining the stiffness needed for precise control of the foils. The composite structure also provides inherent corrosion protection in marine environments and a low radar cross-section, thanks to the materials’ electromagnetic properties.
The autonomous control system must solve a variety of complex, real-time optimisation problems similar to those encountered in robotics and control engineering courses. The platform continually processes sensor data to maintain steady flight above the water and navigate and avoid other objects. This requires implementing sensor fusion algorithms that combine information from multiple sensor types - e.g., radar that detects distant objects; optical systems that provide high-resolution images of objects; and automatic identification system data that broadcasts the positions of other vessels - to form a single representation of the environment. Then, the control software must create a plan of action that meets all constraints imposed on the platform - e.g., maintaining the platform within the hydrofoil flight envelope; avoiding collisions with other objects; minimising energy consumption; and meeting the mission objectives.
There are benefits to electric propulsion that go beyond reducing the acoustic signature. Instant torque response from my electric motors allows rapid acceleration and precise manoeuvrability that would be difficult to achieve with internal combustion engines that require gear reductions. Additionally, eliminating fuel systems, exhaust components, and mechanical transmissions simplifies the platform’s design while reducing maintenance needs - both essential considerations for autonomous platforms without an onboard crew.
MGI's Formula One background guides the structural design approach, where weight savings lead to performance gains. The carbon fibre composite construction enables complex shapes that would be difficult or impossible to produce with traditional marine materials. The high specific stiffness of the carbon fibres allows designers to construct thin, hydrodynamically efficient foil shapes while still meeting structural requirements for dynamic loads.
It is probable that the composite fabrication process employed techniques such as resin transfer moulding and autoclave curing to produce parts with precise fibre orientations that maximise the part’s strength in the direction of the anticipated stresses. This anisotropic design philosophy - tailoring material properties to match anticipated stress distributions - is an example of advanced engineering practices that can optimise performance while minimising weight. The structure can withstand cyclic loading from wave impacts and dynamic loading from foil-generated forces while maintaining the dimensional stability required for hydrofoil performance.
The modular design of the platform, with versions available in lengths of 4 meters, 5 meters, and 6 meters, suggests a scalable engineering architecture. Core systems are identical across all configurations, thereby reducing development costs, simplifying logistics, and enabling customisation to meet the requirements of a specific mission. It is assumed that the larger versions of the platform will provide increased payload capacity and range at the expense of slightly lower maximum speed - trade-offs based on fundamental physical constraints in the design of marine vehicles.
The engineering challenges in developing autonomous docking capability between the SeaGlide and Mosquito UAV platforms include many of the same technical challenges as launching, recovering, and transferring cargo between air and sea platforms in a maritime environment. The autonomous docking capability must account for relative motion between air and sea platforms, wind and wave disturbances, and communication latency. To address these challenges, sophisticated control algorithms must be developed to predict platform motion, compensate for environmental forces, and execute precision manoeuvres without human intervention.
A hybrid-electric version of the platform can address the range limitations associated with battery-only propulsion. A small turbine or internal combustion engine can be used as a range extender to charge batteries during transit while continuing to operate in electric-only mode for quiet operation during mission-critical phases. The primary engineering challenge is to determine the optimal power management strategy - i.e., whether to use battery or generator power based on the mission requirements, sea state, and remaining energy reserves.
Testing of the platform in UK waters, currently underway, will validate its performance across a variety of operational scenarios. Testing will evaluate not only basic functionality but also the platform’s reliability, maintenance requirements, and operational limitations, guiding its deployment. The ability to operate multiple platforms from a single ground control station indicates sophisticated fleet coordination, possibly including swarm algorithms that enable cooperative behaviour among platforms.
As defence organisations continue to evaluate autonomous maritime systems, platforms that successfully integrate these technologies may define new operational paradigms for naval reconnaissance and logistics missions.
TLDR
- SeaGlide is an electric autonomous hydrofoil vessel developed by British firm MGI Engineering for maritime surveillance and logistics
- Hydrofoil technology lifts the hull above water, reducing drag by 80% while maintaining near-silent operation
- Electric propulsion housed in fins provides instant torque response and eliminates acoustic signatures of conventional engines
- Autonomous navigation uses radar, optical sensors, and AIS data with collision-avoidance algorithms for beyond-visual-line-of-sight operation
- Multi-domain integration connects with Mosquito cargo UAVs for autonomous air-sea payload transfers
- Formula One composites provide lightweight, high-strength construction in 4, 5, and 6-meter variants
- Defence applications target intelligence gathering, surveillance, and logistics in contested maritime environments
- Fleet coordination enables multiple vessels to operate from a single ground control station